vinay@robotics: ~/portfolio_ws
VINAY PATIL

Vinay Patil

I build robots that see, move and decide for themselves. Mobile robots on ROS, drones, pan-tilt motion control and computer vision at the edge.

Now · Aug 2023 – present

AiTuring Technologies

Lead Robotics & Software Engineer

I lead the Robotics & Software team building electro-optical, surveillance and robotic systems.

  • Motor control: communication and control for direct-drive pan-tilt platforms over CiA CANopen, Modbus RTU and RS-232, RS-422 and RS-485.
  • Stabilisation: lead servo tuning and control, including a fibre-optic gyro (FOG) stabilisation upgrade.
  • Vision: drones, vehicles and people detected from moving pan-tilt cameras with homography motion compensation, multi-frame differencing and motion prediction. YOLO, VGG and ResNet.
  • Sensor fusion: radar, RF detectors and acoustic sensors cue the electro-optical systems.
  • Quadruped: SLAM navigation, inverse kinematics, dynamics and GPS-denied autonomy.
  • Leadership: run the Robotics & Software function, guide the engineers and drive R&D, system design and technical tenders.

The scene is a generic stand-in: a pan-tilt head tracking a drone and a quadruped walking its loop.

01Autonomous Nursing Robot

SCOBO

A ward robot that does the routine bedside work between nurse rounds. It drives to each bed, checks temperature, pulse and SpO2, hands out medicine from three pill hoppers and lets staff video call the patient.

  • ROS 2 Humble
  • Nav2
  • slam_toolbox
  • AMCL
  • Gazebo
  • Jetson Nano
  • RPLidar A1
  • MLX90640

This is the real URDF and mesh set from the repo, doing a ward round with a live lidar scan.

How it works

Rounds on a schedule

  • Tasks due in the same 15 minute window go into one trip, beds visited in ward order.
  • Thermal camera on the patient's face: frames averaged, hottest pixels give skin temperature.
  • Lidar plus two ultrasonic sensors feed the costmaps and a collision monitor, so low obstacles still stop it.
  • Ward website to admit patients, plan tasks and watch the robot live on the map.
RepoPatent app. 202321076170

02Farm Robot for Tomato Fields

AgriDoc

Maps the field with its lidar, then drives up and down the plant rows on its own. A camera tilted at the ground finds weeds and sprays them. A second camera logs every leaf disease it sees with the robot's position on the map.

  • ROS 2
  • Nav2
  • slam_toolbox
  • YOLOv5
  • TensorFlow
  • Jetson Nano
  • Arduino Mega

Real URDF meshes. Red frustum = weed camera, yellow = leaf camera, pins = logged disease.

Weed and disease patrol

Spot it, spray it

  • Gazebo tomato field, slam_toolbox map, Nav2 path following and a patrol node that sweeps every row.
  • YOLOv5 weed detector and a leaf disease CNN running as ROS 2 nodes on the Jetson.
  • Pump, relay and nozzle on the Arduino Mega for targeted spraying.
RepoPatent app. 202321029972

03Size-Changing Crop Robot

CropSentry

A tracked robot that drives over the crop row, with the plants passing under its body. Linear actuators push the tracks apart and lift the body, so the same robot fits low strawberries and taller plants.

  • ROS 2 Humble
  • Gazebo
  • Nav2
  • robot_localization
  • OpenCV
  • Fusion 360

Real URDF meshes. Cyan = row camera, yellow = disease camera, red = sprayer cameras, red dots = lidar, shaded beds = no-go for Nav2.

Two plots, one robot

Grows to fit the crop

  • Zigzags the strawberry rows at its smallest, then widens and lifts in the gap before the taller plot. Under the body: 0.22 × 0.17 m small, 0.40 × 0.26 m fully grown.
  • Front camera keeps the row centred. Rear camera logs disease with its spot on the map. Two sprayer cameras find weeds beside the crop and the nozzle fires as it passes.
  • Lidar above the plants and Nav2 move it between rows, never across a bed. Encoders and IMU are fused because tracks slip in turns.

04e-Yantra Robotics Competition 2023-24

Luminosity Drone

A drone searches an arena for glowing LED clusters, centres each one in its downward camera, works out the type from the LED count and reports where it is.

  • ROS Noetic
  • Gazebo
  • PID
  • OpenCV
  • scikit-image
  • whycon

Not an animation: this flight is replayed from our Task 2C rosbag. The path and the three detections are the logged data.

Under the hood

Find, centre, report

  • PID on roll, pitch and throttle at 30 Hz from whycon poses of an overhead camera.
  • Grid search, then nudge the setpoint until the cluster is within 5 px of the image centre.
  • On the real drone camera: high threshold, circularity filter and distance grouping of LEDs.

05Rescue and Fire-Watch Drone · HardwareX 2023

Forest-cop-ter

A Raspberry Pi 4 payload on an F450 frame: live camera, GSM calls that pick up on their own, GPS, a first aid box opened by a servo and a fire warning from temperature and humidity.

  • Raspberry Pi 4
  • Python
  • Keras
  • GAN
  • SIM900A
  • Neo-6M
  • Tkinter

On board

One drone, three jobs

  • A small neural network reads temperature and humidity and warns of fire risk. A conditional GAN added 2000 training rows to the UCI forest fire data.
  • Flown to the person, it opens the first aid box with a servo. The GSM module answers calls on its own, so they can talk to the team hands free.
  • One operator GUI over VNC: live camera, GPS position, fire chance, call and box controls.

06DD Robocon 2022 · Lagori · IIT Delhi

R1 & R2

I captained our 20 member team. R1 throws balls like a pitching machine to break the lagori pile. R2 builds it back with vacuum suction cups on a lead screw platform. We scored 80/100.

  • Fusion 360
  • Arduino
  • Mecanum
  • Omni wheels
  • BLDC
  • Steppers
  • RF control

Both robots are the real STEP assemblies from the repo.

Where it started

Two seasons of Robocon

In 2021 our Defence and Throw robots threw arrows into pots. Designed in SolidWorks, built and driven by the club.

Zoomed out · the whole lab

More builds

Person tracking across cameras

CV 2K23 National Hackathon

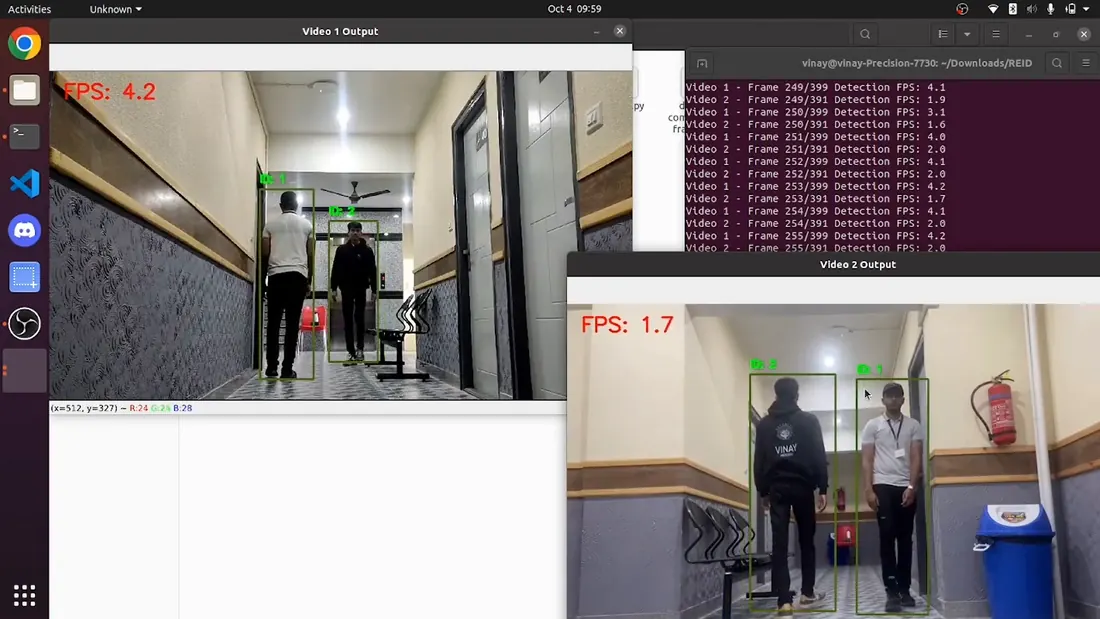
4th of 305 teams. Person tracking and re-identification across overhead cameras, crowd analytics with YOLOv8 and a brain tumour MRI classifier with Grad-CAM.

  • YOLOv8
  • Re-ID
  • Flask
  • Streamlit
Repo
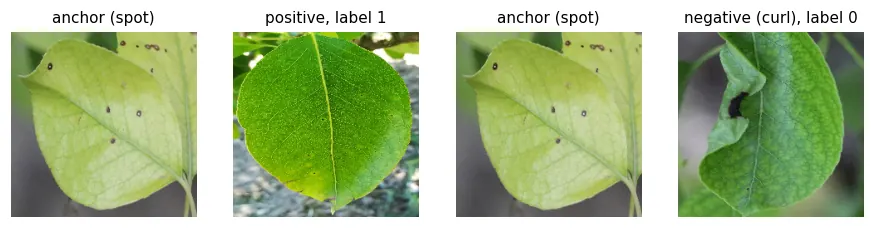
Siamese pairs of pear leaves

Disease Detection on DiaMOS

Pear leaf disease classes with Siamese networks on frozen MobileNetV2 and EfficientNetB0, with a leaf-level split so no leaf leaks into the test set.

  • TensorFlow
  • Siamese
  • EfficientNet
Repo
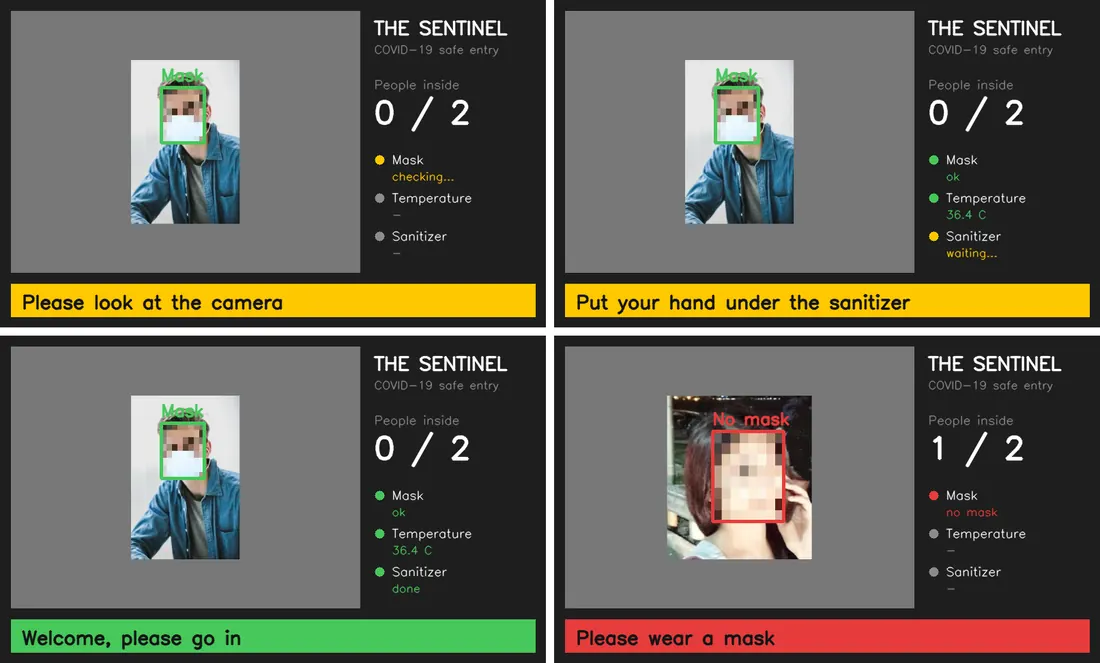
THE SENTINEL entrance screen

THE SENTINEL

Raspberry Pi entry gate that checks for a face mask with a MobileNetV2 TFLite model and body temperature with an MLX90614, plus a staff dashboard.

  • Raspberry Pi
  • TFLite
  • OpenCV
  • Flask
Repo
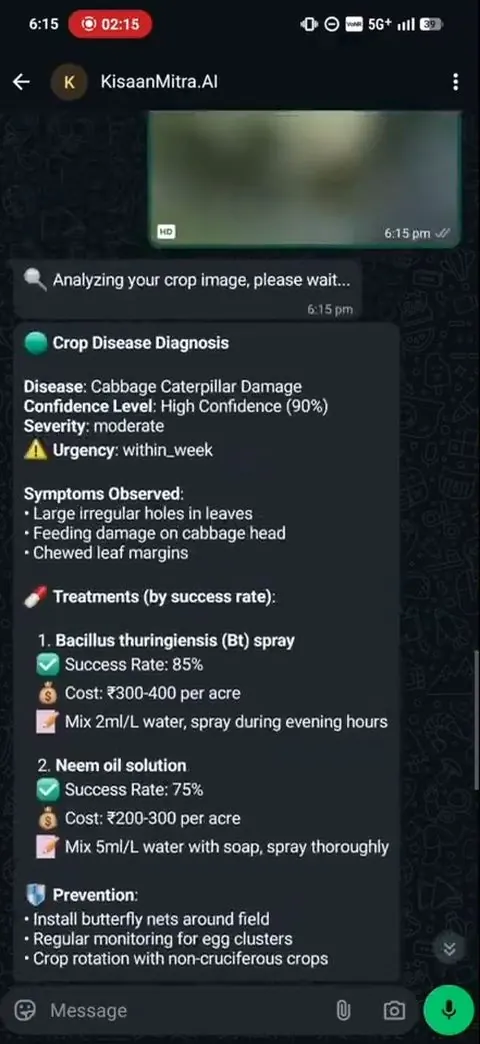
KisaanMitra chat

KisaanMitra.AI

WhatsApp assistant for farmers built for the AWS AI for Bharat hackathon: crop disease from a photo, market prices, weather and budgets.

  • Python
  • WhatsApp API
  • AWS
  • LLM
Repo
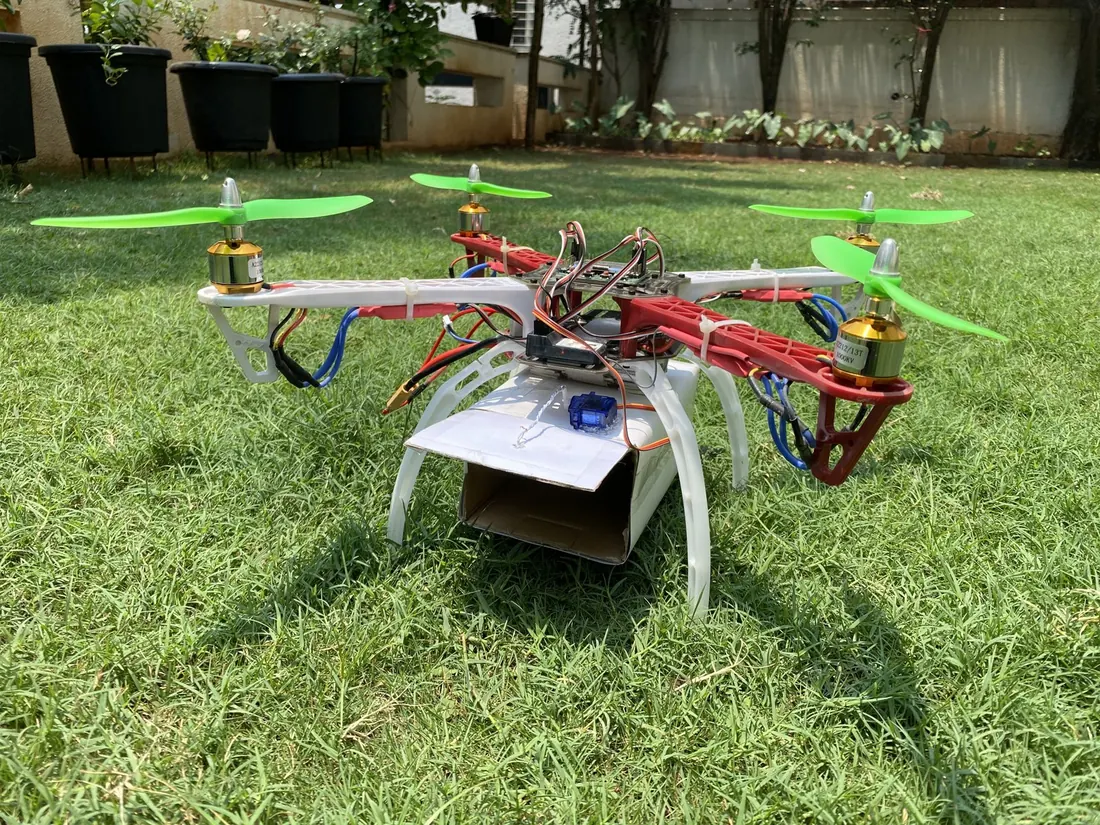
Delivery quadcopter with box

Delivery Quadcopter

Radio controlled F450 on a KK2.1 flight controller that carries a small box and drops it with a servo.

  • F450
  • KK2.1
  • FlySky
Repo
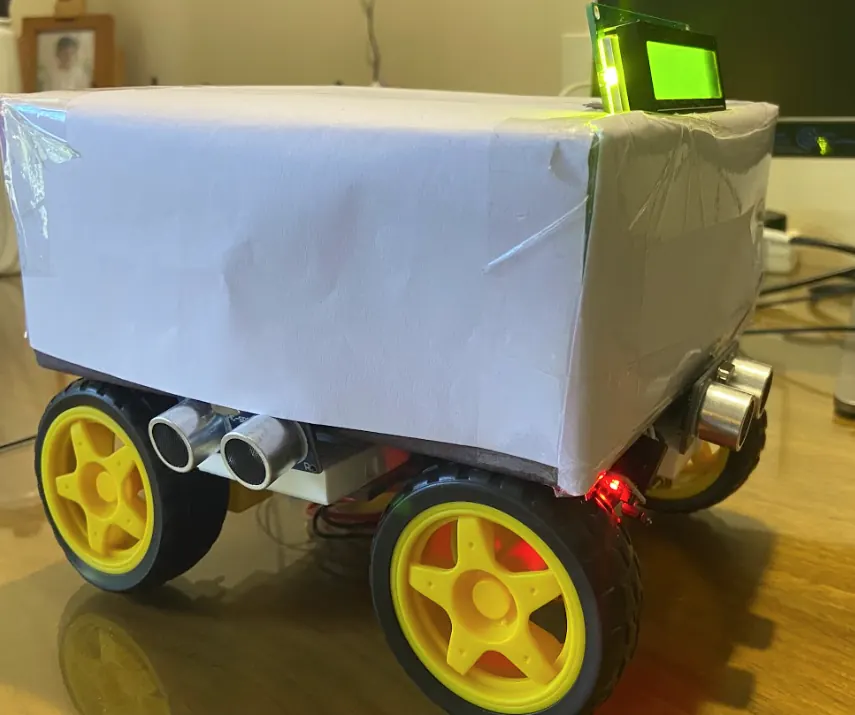
Accident prevention car

Accident Prevention System

Raspberry Pi car that warns the driver with an LED, buzzer and LCD when something comes within 20 cm.

  • Raspberry Pi
  • HC-SR04
  • Python
Repo
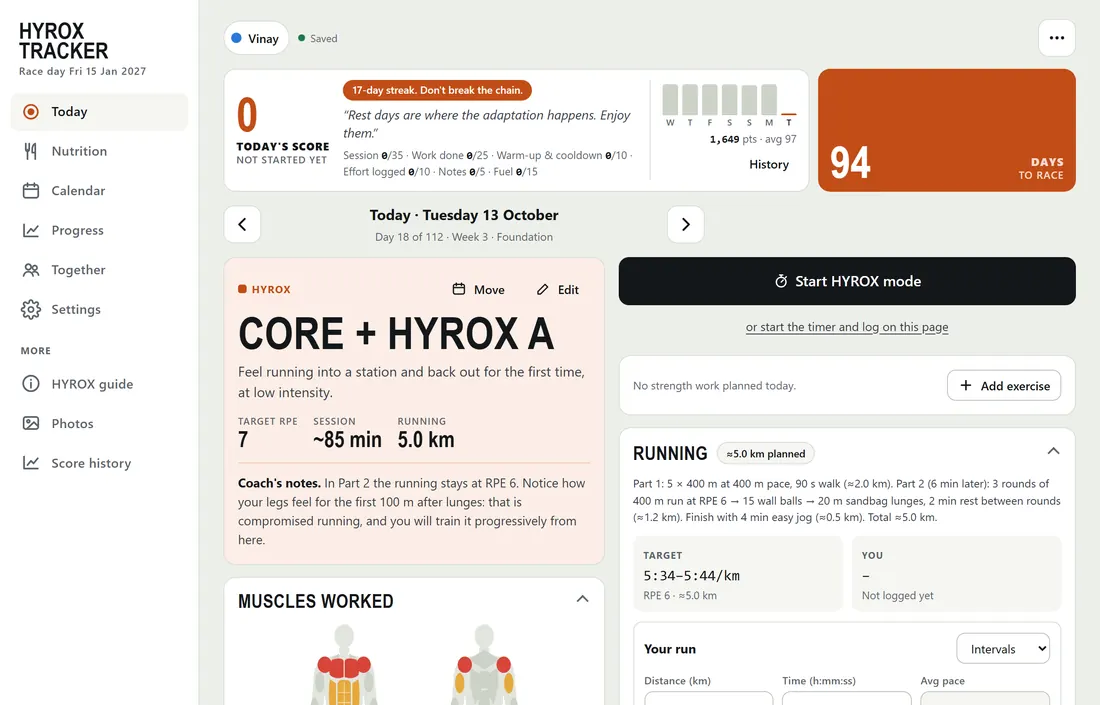
HYROX tracker

HYROX Tracker

Web app for my own 16-week HYROX plan: daily sessions, gym and race modes, progress and race-time prediction.

  • JavaScript
  • Firebase
  • PWA
Repo
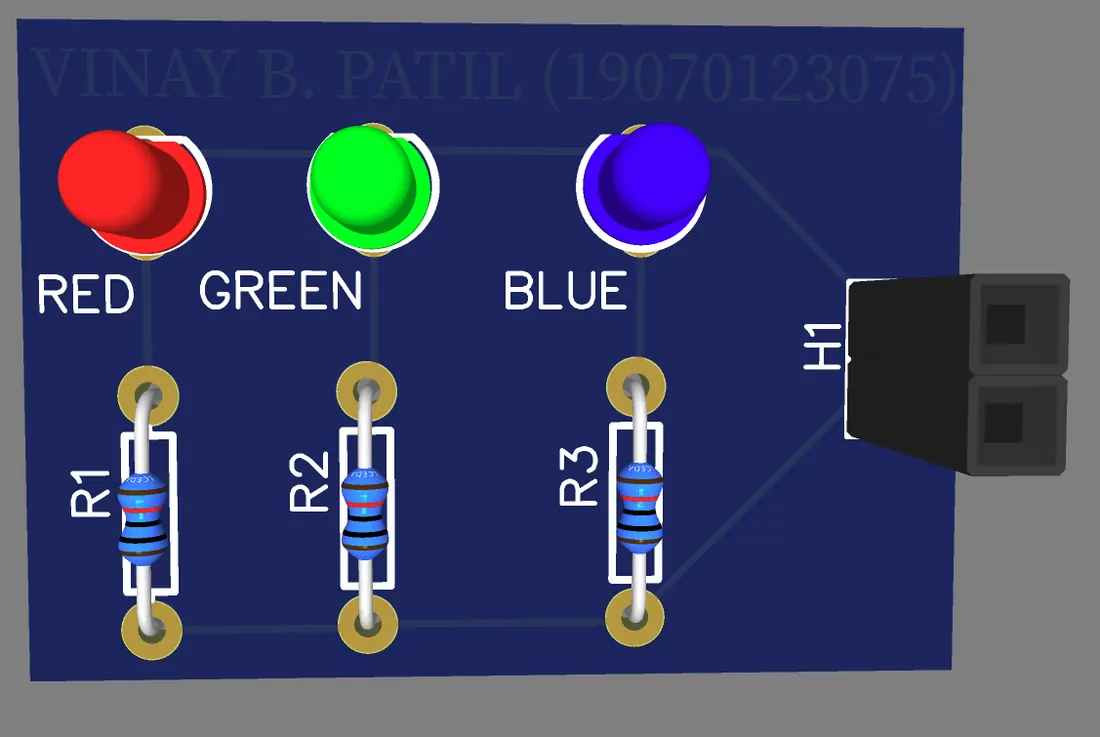
PCB 3D view

PCB Designs

EasyEDA boards: an RGB LED board, a 5V regulator and a dual 12V supply, fabricated in the lab with dry film.

  • EasyEDA
  • KiCad
  • Eagle
Repo
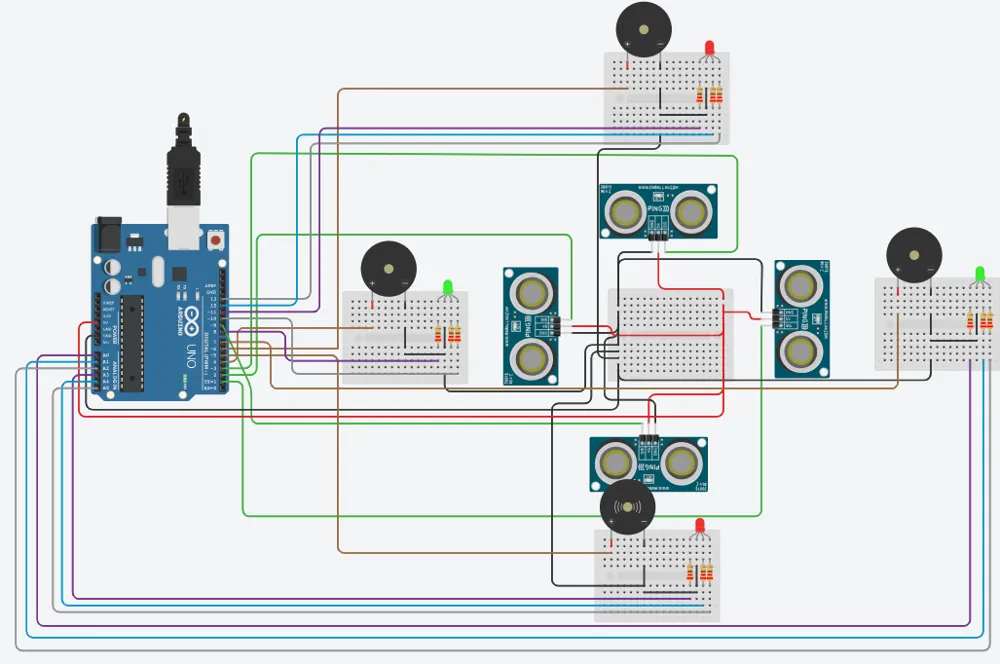
Four-side obstacle warning circuit in Tinkercad

14 Arduino Circuits

Circuits built and simulated in Tinkercad, from LED bars and servos to a keypad calculator, DC motor speed control and a four-side ultrasonic obstacle warning.

  • Arduino Uno
  • Tinkercad
  • C++
Repo

Also on GitHub: Facial Expression Recognition · Face & Eyes in MATLAB · RFID Toll Gate · CIFAR-10 CNN · BNB Forecasting · Shopping Cart in C

/experience

Where I have worked

  1. Lead Robotics & Software Engineer

    AiTuring Technologies

    Lead the Robotics & Software function: pan-tilt motor control over CANopen, FOG stabilisation, moving-camera detection, radar, RF and acoustic cueing, operator software and a quadruped robot. Also guide engineers on estimation algorithms and evaluate technical tenders.

  2. Research Intern

    Symbiosis Centre for Applied Artificial Intelligence

    Crop health management with an autonomous size-adaptive robot (CropSentry): track drive design, leaf disease and weed models and a tele-op web interface.

  3. Intern

    DRDO · Defence Research and Development Organisation

    Servo controller for a helmet-mounted display enslaved camera. Built a helmet with a display and IMU and a motorised pan-tilt camera. Modelled a PMSM plant in Simulink and compared PID, ADRC, adaptive ADRC and sliding mode control; ADRC gave the lowest error, 0.2 mrad.

  4. Intern

    Brabo Robotics and Automation · Tata

    Facial expression recognition with a Haar cascade and a VGG-style CNN on FER2013 that played media to match the mood. GUI in Tkinter, then PyQt5.

Education

B.Tech, Electronics & Telecommunication
Honours in Mechatronics & Automation · Symbiosis Institute of Technology, Pune · 2019 – 2023 · Department rank 3

Diploma in Business Management (minor)
Symbiosis Institute of Business Management · 2021 – 2022

Leadership

President, Rotonity robotics club · Aug 2020 – Jan 2023 · led 50 members, mentoring, planning and finances

Captain, Robocon team · Aug 2021 – Aug 2022 · led 20 through research, planning and budgeting

Student Associate, Placement Cell · Aug 2021 – Jun 2023 · placement drives and resume and interview webinars

Robotics workshops for eight government colleges with Rotonity, Smile Foundation, Atlas Copco and Gnaan U Education · Dec 2023

/publications /patents /awards

Papers, patents & wins

Patents

  • GrantedIndian Patent 598726 · A Remote Monitoring Camera System for Continuous Surveillance
  • Application202421058809 · A Thermal and Visual Imaging Surveillance System
  • Application202321076170 · An Autonomous Healthcare Robot for Patient Health Parameters Monitoring, Medication Dispensing and Remote Interaction
  • Application202321029972 · Autonomous Agricultural Robot for Real-time Detection of Weeds and Diseases in Tomato Plants using NVIDIA Jetson

Publications

  • HardwareXMultipurpose Deep Learning-Powered UAV for Forest Fire Prevention and Emergency Response · 2023 · doi
  • IETAgriDoc: ROS Integrated Agricultural Robot · 6th IET International Smart Cities Symposium, Bahrain · 2022

Wins

  • 4/305National Computer Vision Hackathon · Oct 2023 · person tracking and re-ID
  • 95/100DD Robocon 2021 · Pitch Pot · IIT Delhi
  • 80/100DD Robocon 2022 · Lagori · IIT Delhi
  • 3/140ENTC department rank · Academic Excellence Award 2023
  • 1st3D Model Design · SymbiTech 2022

/skills

Skills

Robotics & Autonomy

  • ROS
  • GMapping
  • Cartographer
  • SLAM Toolbox
  • Nav2
  • AMCL
  • LiDAR
  • Robot Kinematics and Dynamics

Motion Control

  • PID
  • ADRC
  • Adaptive ADRC
  • Sliding-Mode Control
  • Servo Tuning
  • Direct-Drive Motors
  • FOG Stabilisation

Communication Protocols

  • CiA CANopen
  • Modbus RTU
  • Serial: RS-232, RS-422, RS-485

Computer Vision & AI

  • OpenCV
  • Homography
  • Motion Compensation
  • Multi-Frame Differencing
  • YOLO
  • VGG
  • ResNet
  • Object Tracking

Engineering & Integration

  • MATLAB
  • Simulink
  • NVIDIA Jetson
  • IMU
  • Fibre-Optic Gyroscopes
  • Radar
  • RF Detectors
  • Acoustic Sensors

/certificates

Certificates

Show 27 more certificates
Vinay Patil

/contact

Let's build something that moves.

Robotics, motion control, perception or a sim like this one. My inbox is open.